شركة ونزهو برانس للمعدات الهيدروليكية المحدودة


cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
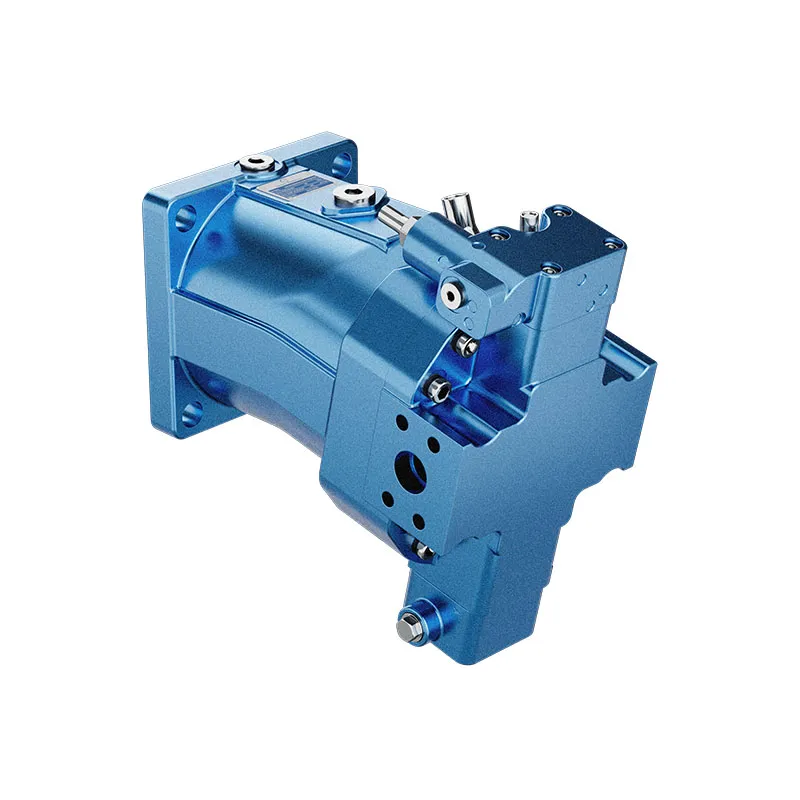
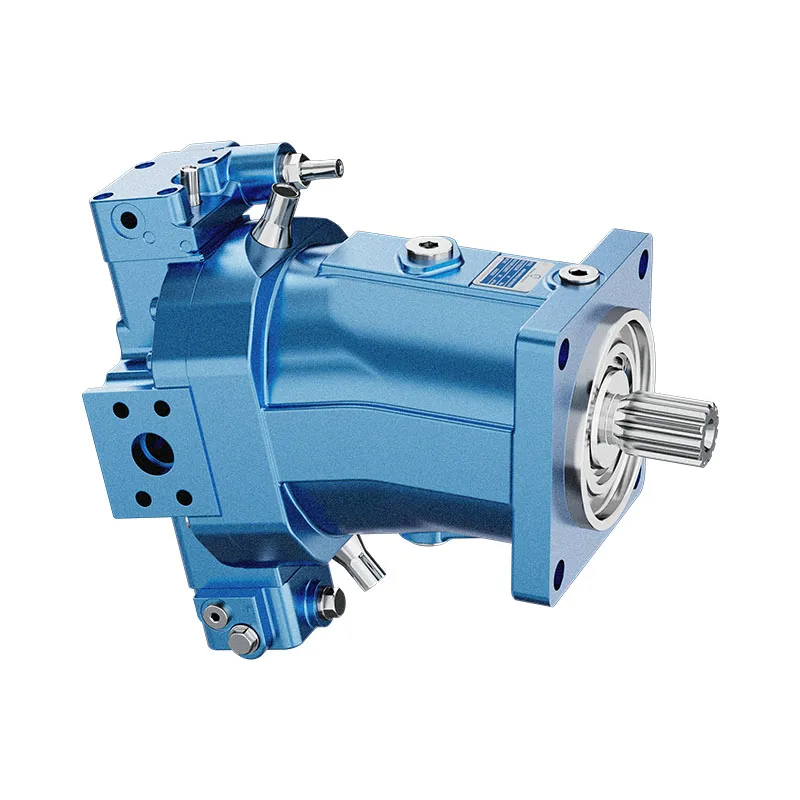
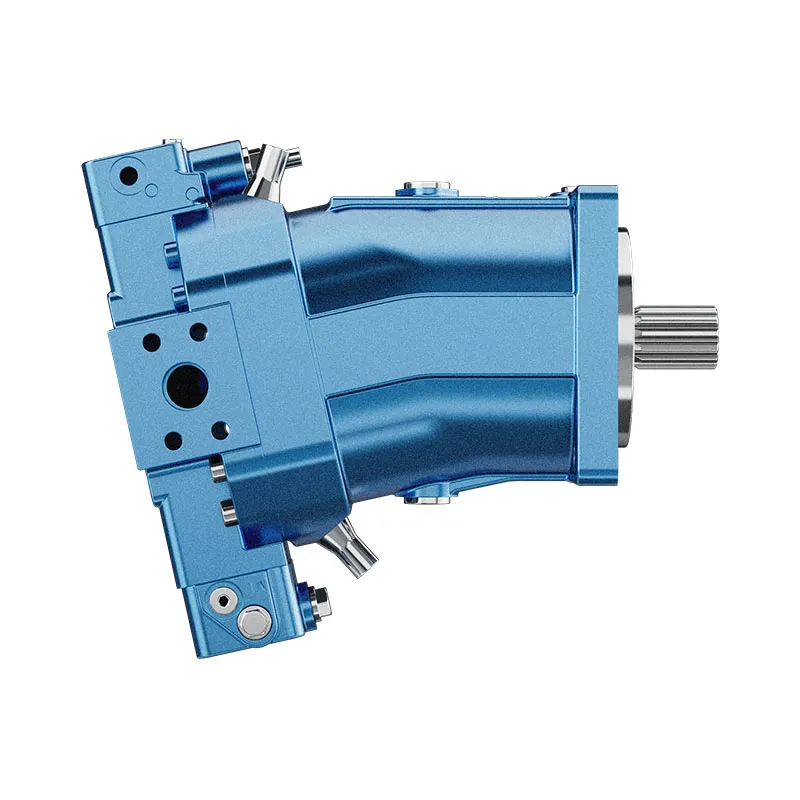
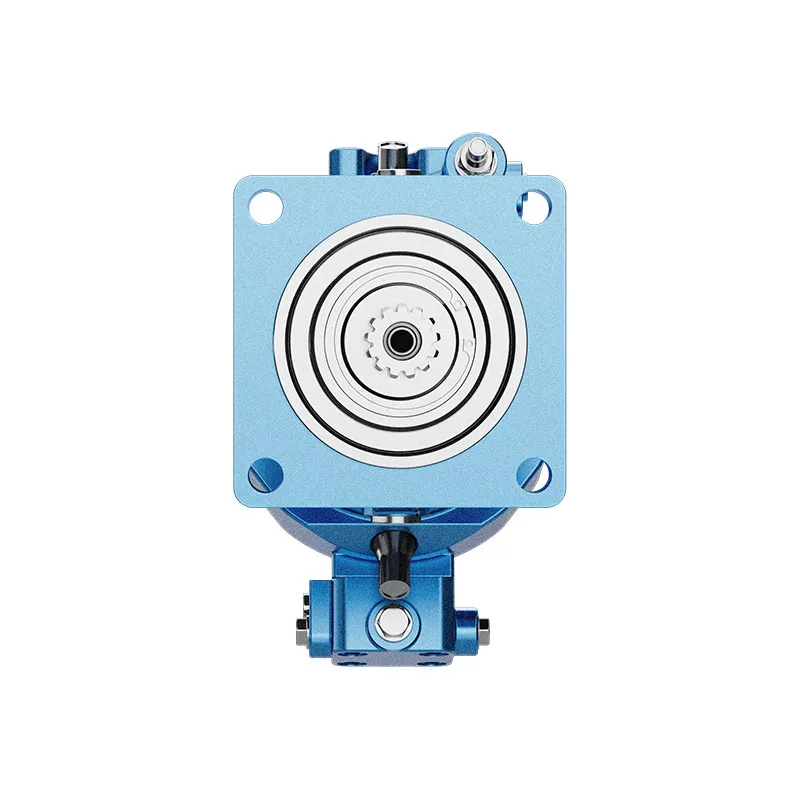
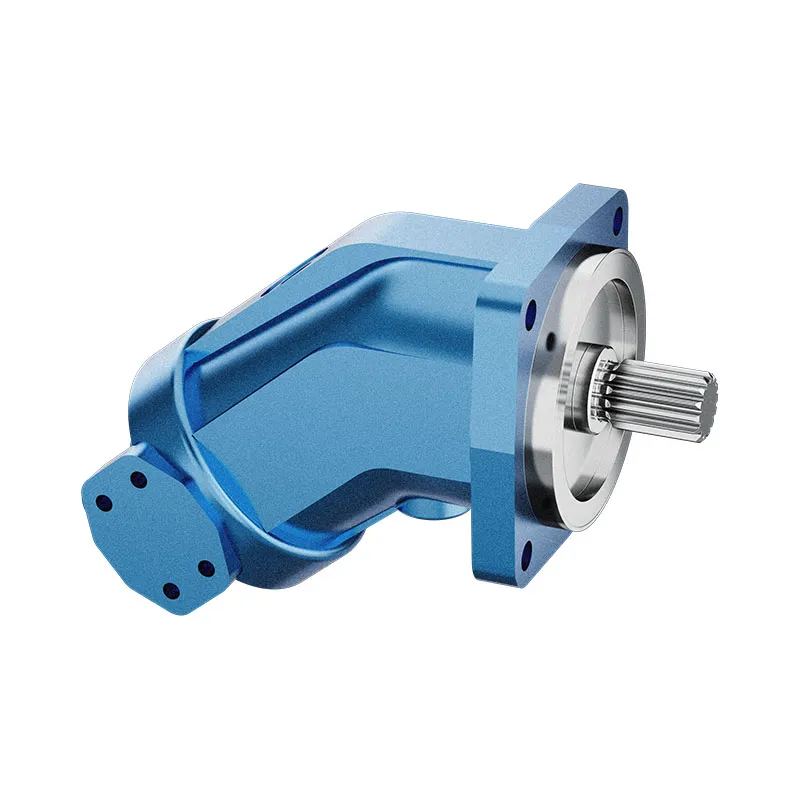
The AA6VM variable displacement bent-axis motor changes the torque-speed relationship by changing displacement. The technical table covers nominal size 250; it is not a complete rating table for all AA6VM sizes.
- محرك ذات محور منحني متغير
- Displacement-control options
- Flushing and boost valve options
- Counterbalance arrangement requires confirmation
PRANCE HYDRAULIC · PRODUCT SERIES
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
Axial piston; bent axis, variable displacement · Confirm open or closed circuit configuration
The AA6VM variable displacement bent-axis motor changes the torque-speed relationship by changing displacement. The technical table covers nominal size 250; it is not a complete rating table for all AA6VM sizes.
Model
✓
Request a Quotationعرض البيانات الفنية وورقة البياناتAA6VMAxial piston; bent axis, variable displacement
Confirm the complete model and approved specification with Prance Hydraulic. Product-series references alone do not establish interchangeability.
Configuration review · Technical documentation · Product selection
تفاصيل المنتج
- محرك ذات محور منحني متغير
- Displacement-control options
- Flushing and boost valve options
- Counterbalance arrangement requires confirmation
CATEGORIES: محرك مكبس, محرك مكبس متغير الإزاحة
AA6VM Features & Application
محرك ذات محور منحني متغير
Specify the displacement range or switching arrangement and verify performance at each required setting.
Displacement-control options
Match the complete control option and its command requirements to the existing controller. Similar housings can use different control arrangements.
Flushing and boost valve options
Account for pilot or replenishment demand and the relevant pressure limits. Include filtration and the return or drain route in the circuit review.
Counterbalance arrangement requires confirmation
Specify the full MS order code, installation drawing and operating duty so the quotation can identify the proposed configuration.
AA6VM Specifications
| Series / model | AA6VM |
|---|---|
| Product type | cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits |
| تصميم | Axial piston; bent axis, variable displacement |
| Circuit / selection | Confirm open or closed circuit configuration |
| Technical table scope | Nominal size 250 |
| Listed maximum displacement | 250 cm³/rev |
| Minimum displacement and controls | Confirm the selected setting and full model code |
AA6VM Selection & Configuration
The AA6VM variable displacement bent-axis motor changes the torque-speed relationship by changing displacement. The technical table covers nominal size 250; it is not a complete rating table for all AA6VM sizes.
Specify the maximum and minimum displacement settings, control mode and response on loss of command. A small displacement increases speed for a given flow but reduces torque at the same pressure difference. Check flushing, replenishment and braking requirements for the circuit.
Your Application.
The Right Configuration.
Hydraulic pumps · Hydraulic motors · Hydraulic valves
Send the MS nameplate, operating requirements and installation drawing for a configuration review before quoting.
- Model review — send the full model code or an existing nameplate photograph.
- Interface matching — confirm shaft, mounting flange, rotation and ports.
- Operating conditions — provide flow, pressure, speed, fluid and duty cycle.
- Documentation — request the relevant product data and drawings for your review.

AA6VM Buying Guide
Use this sequence to prepare the AA6VM configuration for review and quotation.
- Define starting and continuous torque, speed range and duty cycle.
- Specify available flow, work-port pressure difference and return pressure.
- Confirm the displacement setting and required behavior during starting and stopping.
- Check shaft, mounting pilot, flange, port orientation and external loads.
- Review case drainage, replenishment and any displacement control.
- Specify fluid conditions and any independent braking requirement.
- Approve the complete model, operating envelope, drawing and quantity.
Selection, Documentation & Project Support

Selection Support
Learn more →Share your hydraulic circuit, operating point and installation requirements for a configuration discussion.
Flow · Pressure · Speed · Interfaces

Technical Resources
Learn more →Review product documentation, model codes and technical data before finalizing the specification.
Datasheets · Model codes · Drawings

Project Inquiries
Learn more →Send your required model, quantity, application and project requirements to discuss your inquiry.
Product inquiries · Configuration review
Configuration, Quantity & Delivery
Confirm the complete MS code, approved drawing and operating limits. Availability, quantity, documentation and delivery date are confirmed in the quotation.
Discuss Your AA6VM Application
Send the full model code, operating duty, installation details and quantity.
Request a AA6VM QuotationAA6VM Questions Before Ordering
What type of product is the AA6VM?
AA6VM Variable Displacement Bent Axis Motor. Design: Axial piston; bent axis, variable displacement. Confirm open or closed circuit configuration. Confirm the complete order code for the offered version.
Can a similar motor replace the AA6VM?
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits.
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits.
AA6VM Technical Data & Documents
View AA6VM catalog data and operating conditions
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits.
البيانات الفنية
| حجم | غير مقبول | 250 | ||
| الإزاحة الهندسية، لكل دورة1) | Vجي ماكس | in3 | 15.26 | |
| سم3 | 250 | |||
| Vج مين | in3 | 0 | ||
| سم3 | 0 | |||
| Vg x | in3 | 12.51 | ||
| سم3 | 205 | |||
| السرعة الدورانية القصوى2) (مع الالتزام بأقصى تدفق للمدخل المسموح به) | عند Vجي ماكس | nالاسمية | دورة في الدقيقة | 2700 |
| عند Vg<Vgx | nالحد الأقصى | دورة في الدقيقة | 3300 | |
| عند Vg 0 | nالحد الأقصى | دورة في الدقيقة | يرجى الاتصال بنا | |
| تدفق المدخل | عند nالاسمية و Vجي ماكس | qv الأقصى | gpm | 178 |
| ل/دقيقة | 675 | |||
| عزم الدوران3) | عند Vجي ماكس و Δp = 5800 رطل-بوصة مربعة (400 بار) | T | رطل-قدم | – |
| لا شيء جديد | – | |||
| عند Vجي ماكس و Δp = 5100 رطل-بوصة مربعة (350 بار) | رطل-قدم | 1026 | ||
| لا شيء جديد | 1391 | |||
| صلابة الدوران | Vجي ماكس إلى Vg/2 | Cالحد الأدنى | رطل-قدم/راديان | |
| ك.ن.م/راديان | 60 | |||
| Vg/2 إلى 0 (مُInterpolated) | Cالحد الأدنى | رطل-قدم/راديان | ||
| ك.ن.م/راديان | 181 | |||
| عزم القصور الذاتي للمجموعة الدوارة | JTW | رطل-قدم2 | 1.448 | |
| كجم متر2 | 0.061 | |||
| التسارع الزاوي الأقصى | α | راديان/ثانية2 | 10000 | |
| حجم الحالة | V | غالون | 0.79 | |
| l | 3.0 | |||
| الوزن، تقريبًا. | m | رطل | 220 | |
| kg | 100 | |||
نطاق السرعة
السرعة الدورانية الدنيا nالحد الأدنى is not restricted. Please consult us regarding applications requiring uniformity of the rotatory motion at low speeds. ▼Permissible displacement in relation to speed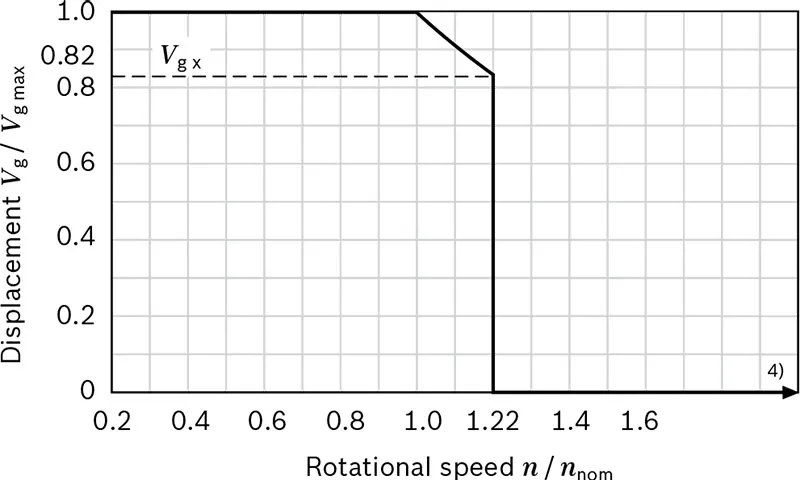
ملاحظات
▶Theoretical values, without efficiency and tolerances;values rounded ▶Operation above the maximum values or below the minimum values may result in a loss of function, a reduced service life or in the destruction of the axial piston unit. Other permissible limit values, such as speed variation, reduced angular acceleration as a function of the frequency and the permissible angular acceleration at start (lower than the maximum angular acceleration) can be found in data sheet 90261.تحديد خصائص التشغيل
| تدفق المدخل | qv=(Vg×n)/(231×ηv) | [غالون/دقيقة] | ((Vg×n)/(1000×ηv)) | [ل/دقيقة] |
| سرعة الدوران | n=(qv×231×ηv)/Vg | [rpm] | ((qv×1000×ηv)/Vg) | [rpm] |
| عزم الدوران | T=(Vg×Δp×ηمم)/(24×π) | [رطل-قدم] | ((Vg×Δp×ηمم)/(20×π)) | [نيوتن متر] |
| طاقة | P=(2π×T×n)/33000=(qv×Δp×ηt)/1714 | [حصان] | ((2π×T×n)/60000=(qv×Δp×ηt)/600) | [ك.و] |
| Key Vg=الإزاحة لكل دورة [بوصة مكعبة]3 (سم3)] Δp=Differential pressure [psi (bar)] n=Rotational speed [rpm] ηv=Volumetric efficiencyI ηمم=Mechanical-hydraulic efficiency ηt=الكفاءة الكلية (nt=ny·nmh) | ||||
القوى الشعاعية والمحورية المسموح بها على عمود القيادة
| حجم | غير مقبول | 250 | ||
| عمود الدوران | قطر | in | 2 | |
| أقصى قوة شعاعية عند المسافة أ (من طوق العمود المرفقي) | 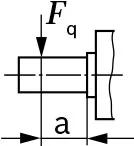 |
Fq الحد الأقصى | lb | 2701) |
| N | 12001) | |||
| a | in | 1.32 | ||
| mm | 33.5 | |||
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limitsq الحد الأقصى | Tq الحد الأقصى | رطل-قدم | 2) | |
| لا شيء جديد | 2) | |||
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limitsجي ماكس و Fq الحد الأقصى | Δpq الحد الأقصى | رطل لكل بوصة مربعة | 2) | |
| بار | 2) | |||
| أقصى قوة محورية عند التوقف أو التشغيل بدون ضغط | 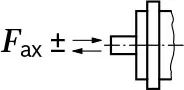 |
+Fax max | lb | 0 |
| N | 0 | |||
| -Fax max | lb | 270 | ||
| N | 1200 | |||
| القوة المحورية المسموح بها لكل ضغط (بار) ضغط العمل | +Fax perm/bar | رطل/باسكال | 2) | |
| N/bar | 2) | |||
إشعارات
▶The values given are maximum values and do not apply to continuous operation. ▶The permissible axial force in -Fax direction is to be avoided, because thereby the bearing life is reduced. ▶Special requirements apply in the case of belt drives.Please contact us. Effect of radial force Fq cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits By selecting a suitable direction of radial force Fa, the load on the bearings, caused by the internal rotary group forces can be reduced, thus optimizing the service life of the bearings. Recommended position of mating gear is dependent on direction of rotation. Example: ▼Toothed gear output drive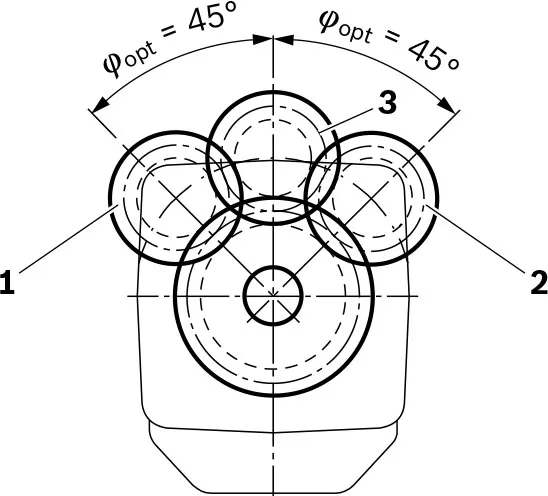 1 Direction of rotation “counter-clockwise”, pressure at port B
2 Direction of rotation “clockwise”, pressure at port A
3 Bidirectional direction of rotation
1) When at standstill or when axial piston unit working in depressurized conditions. Higher forces are permissible under pressure,please contact us.
2) Please contact us.
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
Related Selection Resources
Request a AA6VM Quotation
أخبرنا بالتكوين المطلوب، الكمية والتطبيق.
المنتجات ذات الصلة
Compare related hydraulic motors and confirm the complete configuration for your application.
اكتب رمزاً
| 01 | 02 | 03 | 04 | 05 | 06 | 07 | 08 | 09 | 10 | 11 | 12 | 13 | 14 | 15 | 16 | 17 | 18 | 19 | 20 | |||
| AA6V | M | 250 | / | 63 | W | - | V | S | D | - |
السائل الهيدروليكي
| 01 | زيت معدني وHFD. HFD فقط مع استخدام كراسي طويلة العمر "L" (بدون رمز) | |
| سائل هيدروليكي HFB، HFC فقط بالتزامن مع كراسي طويلة العمر “L” | E |
وحدة كباس محوري
| 02 | تصميم محور منحنى، متغير، الضغط الاسمي 5100 رطل/بوصة مربعة (350 بار)، أقصى ضغط 5800 رطل/بوصة مربعة (400 بار) | AA6V |
تحمل عمود القيادة
| 03 | تحمل قياسي (بدون رمز) | |
| تحمل طويل العمر | L |
نمط التشغيل
| 04 | محرك (محرك مركب A6VE) | M |
الحجم (NG)
| 05 | الإزاحة الهندسية | بالسنتيمتر3/دورة في الدقيقة | 250 |
| بالإنش3/دورة في الدقيقة | 15.25 |
جهاز تحكم
| 06 | التحكم النسبي الهيدروليكي | ΔPst= 145 رطل لكل إنش مربع (10 بار) | HD1 |
| ΔPst= 365 رطل لكل إنش مربع (25 بار) | HD2 | ||
| ΔPst= 510 رطل لكل إنش مربع (35 بار) | HD3 | ||
| التحكم الكهربائي النسبي1) | U=12 فولت تيار مستمر | EP1 | |
| U=24 فولت تيار مستمر | EP2 | ||
| التحكم الثنائي النقاط الهيدروليكي | HZ | ||
| التحكم الثنائي النقاط الكهربائي1) | U=12 فولت تيار مستمر | إي زي 1 | |
| U=24 فولت تيار مستمر | EZ2 | ||
| التحكم التلقائي عالي الضغط ذات الصلة | مع زيادة ضغط الحد الأدنى Δp ≤ تقريبا 145 رطل لكل إنش مربع (10 بار) | HA1 | |
| مع زيادة ضغط Δp= 1450 رطل لكل إنش مربع (100 بار) | HA2 | ||
| التحكم التلقائي المرتبط بسرعة pst/ pعالي الدقة=3/100 | صمام اتجاه الحركة الهيدروليكي | دا |
التحكم في الضغط / التجاوز (فقط لـ HD، EP)
| 07 | بدون تحكم في الضغط / التجاوز | ||
| إعداد ثابت للتحكم في الضغط | إعداد ثابت | D | |
| تجاوز هيدروليكي، نقطتين | E2) | ||
| تحكم عن بعد هيدروليكي، تناسبي | G | ||
تجاوزات للتحكمات HA1 و HA2
| 08 | بدون تجاوز | |
| تجاوز هيدروليكي، تحكم عن بعد، تناسبي | T |
مسلسل
| 09 | السلسلة 6، الفهرس 3 | 63 |
اتجاه الدوران
| 10 | مشاهد على عمود القيادة، ثنائي الاتجاه | W |
تحديد نطاق الإزاحة3)
| 11 | Vج مين = 0 إلى 0.4 فولتجي ماكس Vجي ماكس=Vجي ماكس إلى 0.8 فولتجي ماكس | 1 |
| Vجي ماكس > 0.4 فولتجي ماكس إلى 0.8 فولتجي ماكس Vجي ماكس=Vجي ماكس إلى 0.8 فولتجي ماكس | 2 |
•=متوفر ○=عند الطلب -=غير متوفر
1) موصل هيرشمان القياسي
2) مجهز كمعيار مع الإصدار د
3) يرجى تحديد الإعدادات الدقيقة لـ Vg الحد الأدنى و Vجي ماكس عند الطلب: Vg الحد الأدنى = ... في3 (سم3), فولتg الحد الأقصى = ... في3 (سم3)
مادة مانعة للتسرب
| 12 | FKM (إيلاستومر فلوري) | V |
عمود الدوران
| 13 | عمود مسنن ANSI B92.1a | S |
شفة التركيب
| 14 | SAE J744 -4-برغي 165-4 | D |
منفذ عامل4)
| 15 | منافذ العمل SAE أ و ب في الخلف | 51 | 0 | ● | 510 |
| 7 | ● | 517 | |||
| منافذ العمل SAE أ و ب على الجانب، مقابل | 52 | 0 | ● | 520 | |
| 7 | ● | 527 |
الصمامات: 0=بدون صمام 7=صمام التنظيف وزيادة ضغط الدفع، مركب
حساس السرعة
| 16 | بدون حساس سرعة (بدون رمز) | ||
| مجهز لحساس سرعة القرص الصلب | ▲ | F | |
| مستشعر سرعة القرص الصلب مركب5) | ▲ | H |
مستشعر زاوية الدوران
| 17 | بدون مستشعر زاوية الدوران (بدون رمز) | |
| مستشعر زاوية الدوران البصرية | V | |
| مستشعر زاوية الدوران الكهربائي | E |
بداية التحكم
| 18 | عند Vج مين (المعيار لـ HA) | A |
| عند Vجي ماكس (المعيار لـ HD، HZ، EP، EZ، DA) | B |
نسخة قياسية / خاصة
| 19 | الإصدار القياسي | 0 |
| الإصدار الخاص | -S |
•=متوفر ○=عند الطلب ▲=غير متاح للمشاريع الجديدة -=غير متوفر
إشعارات
▶ملاحظة ملاحظات تخطيط المشروع
▶عند الطلب، يرجى تقديم البيانات الفنية ذات الصلة بالإضافة إلى رمز النوع.
4) خيوط التثبيت، SAE
5) تحديد رمز النوع بشكل منفصل للمستشعر وفقًا لورقة البيانات 95135 - HDD ومراعاة متطلبات الإلكترونيات.
البيانات الفنية
| حجم | غير مقبول | 250 | ||
| الإزاحة الهندسية، لكل دورة1) | Vجي ماكس | in3 | 15.26 | |
| سم3 | 250 | |||
| Vج مين | in3 | 0 | ||
| سم3 | 0 | |||
| Vg x | in3 | 12.51 | ||
| سم3 | 205 | |||
| السرعة الدورانية القصوى2) (مع الالتزام بأقصى تدفق للمدخل المسموح به) | عند Vجي ماكس | nالاسمية | دورة في الدقيقة | 2700 |
| عند Vg<Vgx | nالحد الأقصى | دورة في الدقيقة | 3300 | |
| عند Vg 0 | nالحد الأقصى | دورة في الدقيقة | يرجى الاتصال بنا | |
| تدفق المدخل | عند nالاسمية و Vجي ماكس | qv الأقصى | gpm | 178 |
| ل/دقيقة | 675 | |||
| عزم الدوران3) | عند Vجي ماكس و Δp = 5800 رطل-بوصة مربعة (400 بار) | T | رطل-قدم | - |
| لا شيء جديد | - | |||
| عند Vجي ماكس و Δp = 5100 رطل-بوصة مربعة (350 بار) | رطل-قدم | 1026 | ||
| لا شيء جديد | 1391 | |||
| صلابة الدوران | Vجي ماكس إلى Vg/2 | Cالحد الأدنى | رطل-قدم/راديان | |
| ك.ن.م/راديان | 60 | |||
| Vg/2 إلى 0 (مُInterpolated) | Cالحد الأدنى | رطل-قدم/راديان | ||
| ك.ن.م/راديان | 181 | |||
| عزم القصور الذاتي للمجموعة الدوارة | JTW | رطل-قدم2 | 1.448 | |
| كجم متر2 | 0.061 | |||
| التسارع الزاوي الأقصى | α | راديان/ثانية2 | 10000 | |
| حجم الحالة | V | غالون | 0.79 | |
| l | 3.0 | |||
| الوزن، تقريبًا. | m | رطل | 220 | |
| kg | 100 | |||
نطاق السرعة
السرعة الدورانية الدنيا nالحد الأدنى is not restricted. Please consult us regarding applications requiring uniformity of the rotatory motion at low speeds.
▼الإزاحة المسموح بها بالنسبة إلى السرعة
ملاحظات
▶القيم النظرية، بدون الكفاءة والتحملات؛ القيم مقربة
▶العمل فوق القيم القصوى أو تحت القيم الدنيا قد يؤدي إلى فقدان الوظيفة، تقليل عمر الخدمة أو تدمير وحدة المكبس المحوري. يمكن العثور على قيم الحد المسموح بها الأخرى، مثل تغير السرعة، تقليل التسارع الزاوي كوظيفة للتردد والتسارع الزاوي المسموح عند البدء (أقل من التسارع الزاوي الأقصى) في ورقة البيانات 90261.
تحديد خصائص التشغيل
| تدفق المدخل | qv=(Vg×n)/(231×ηv) | [غالون/دقيقة] | ((Vg×n)/(1000×ηv)) | [ل/دقيقة] |
| سرعة الدوران | n=(qv×231×ηv)/Vg | [rpm] | ((qv×1000×ηv)/Vg) | [rpm] |
| عزم الدوران | T=(Vg×Δp×ηمم)/(24×π) | [رطل-قدم] | ((Vg×Δp×ηمم)/(20×π)) | [نيوتن متر] |
| طاقة | P=(2π×T×n)/33000=(qv×Δp×ηt)/1714 | [حصان] | ((2π×T×n)/60000=(qv×Δp×ηt)/600) | [ك.و] |
| مفتاح Vg=الإزاحة لكل دورة [بوصة مكعبة]3 (سم3)] Δp=فرق الضغط [رطل لكل بوصة مربعة (بار)] n=Rotational speed [rpm] ηv=الكفاءة الحجمية ηممcURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits ηt=الكفاءة الكلية (nt=ny·nmh) |
||||
1) يمكن ضبط الحد الأدنى والحد الأقصى للإزاحة بشكل تدريجي دون خطوات، راجع رمز النوع. (الإعداد القياسي في حالة عدم وجود رمز الطلب: Vg الحد الأدنى = 0.2 × Vg الحد الأقصى, Vجي ماكس = Vg الحد الأقصى).
2) The values are applicable:
- لنطاق اللزوجة المثالي من νاختيار = 170 إلى 75 SUS (36 إلى 16 مم2/s)
- with hydraulic fluid based on mineral oils
3) عزم الدوران بدون قوة شعاعية، مع قوة شعاعية.
4) القيم في هذا النطاق عند الطلب
القوى الشعاعية والمحورية المسموح بها على عمود القيادة
| حجم | غير مقبول | 250 | ||
| عمود الدوران | قطر | in | 2 | |
| أقصى قوة شعاعية عند المسافة أ (من طوق العمود المرفقي) | |
Fq الحد الأقصى | lb | 2701) |
| N | 12001) | |||
| a | in | 1.32 | ||
| mm | 33.5 | |||
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limitsq الحد الأقصى | Tq الحد الأقصى | رطل-قدم | 2) | |
| لا شيء جديد | 2) | |||
| cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limitsجي ماكس و Fq الحد الأقصى | Δpq الحد الأقصى | رطل لكل بوصة مربعة | 2) | |
| بار | 2) | |||
| أقصى قوة محورية عند التوقف أو التشغيل بدون ضغط | |
+Fax max | lb | 0 |
| N | 0 | |||
| -Fax max | lb | 270 | ||
| N | 1200 | |||
| القوة المحورية المسموح بها لكل ضغط (بار) ضغط العمل | +Fax perm/bar | رطل/باسكال | 2) | |
| N/bar | 2) | |||
إشعارات
▶ القيم المعطاة هي القيم القصوى ولا تنطبق على التشغيل المستمر.
▶ يجب تجنب القوة المحورية المسموح بها في اتجاه -Fax، لأنها تقلل من عمر الحامل.
cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits.
Effect of radial force Fq cURL Too many subrequests by single Worker invocation. To configure this limit, refer to https://developers.cloudflare.com/workers/wrangler/configuration/#limits
عن طريق اختيار اتجاه مناسب للقوة الشعاعية Fa، يمكن تقليل الحمل على الكراسي، الناتج عن قوى المجموعة الدوارة الداخلية، وبالتالي تحسين عمر الخدمة للكراسي. يعتمد الموقع الموصى به للتروس المتطابقة على اتجاه الدوران. مثال:
▼محرك التروس المسننة
1 اتجاه الدوران "عكس عقارب الساعة"، الضغط عند المنفذ B
2 اتجاه الدوران "مع عقارب الساعة"، الضغط عند المنفذ A
3 اتجاه دوران ثنائي الاتجاه
1) عند التوقف أو عند تشغيل وحدة المكبس المحوري في ظروف بدون ضغط. يمكن السماح بقوى أعلى تحت الضغط، يرجى الاتصال بنا.
2) يرجى الاتصال بنا.
